Kush Garg
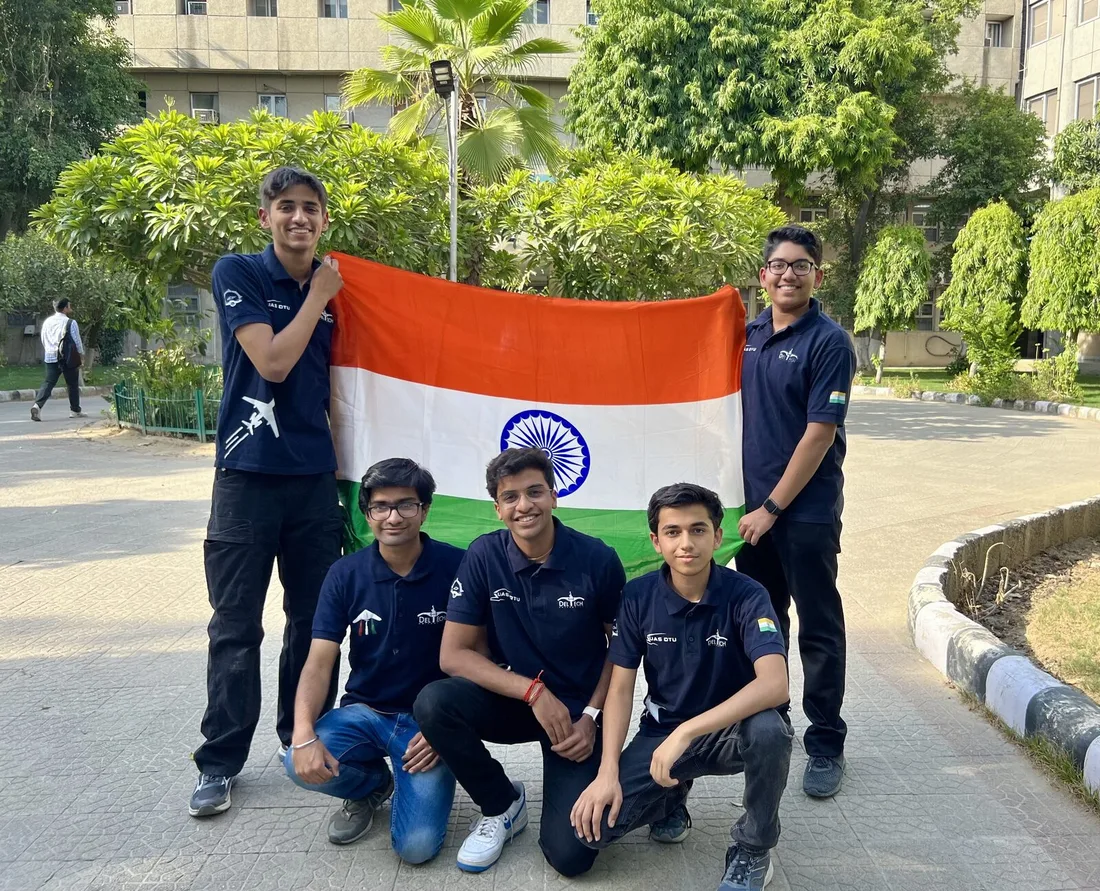
I’m a Mathematics and Computing undergraduate at Delhi Technological University (DTU), working in applied robotics and autonomy. I have interned at General Autonomy as a Robotics Autonomy Engineer, developing semantic exploration, terrain-aware planning, and visual-inertial odometry for quadrupeds. I’ve also interned at MIT Media Lab on non-line-of-sight perception. With UAS-DTU, I placed 2nd at the DARPA Triage Challenge 2024 (USA) and 3rd globally at ICUAS in Greece.
My technical work spans autonomous exploration and navigation, SLAM, sensor fusion, visual-inertial odometry, deep learning (GANs, LaMa), physics simulation, and UAV systems and avionics.
I enjoy building and deploying products, robots, and drones, taking ideas from concept to real-world systems. Outside of work, you’ll usually find me flying drones or playing table tennis.
News
- 08/2026 Won 1st place nationally and a ₹6 lakh scholarship at the IET India Scholarship Award 2026.
- 07/2026 Completed a Robotics Autonomy Engineer internship at General Autonomy.
- 03/2026 Scaled RenderPerk to six-figure monthly revenue.
- 01/2026 Founded RenderPerk, a distributed compute rendering platform.
- 06/2025 Joined MIT Media Lab as a Research Intern.
- 05/2025 Paper accepted at ICUAS 2025 in Charlotte, NC.
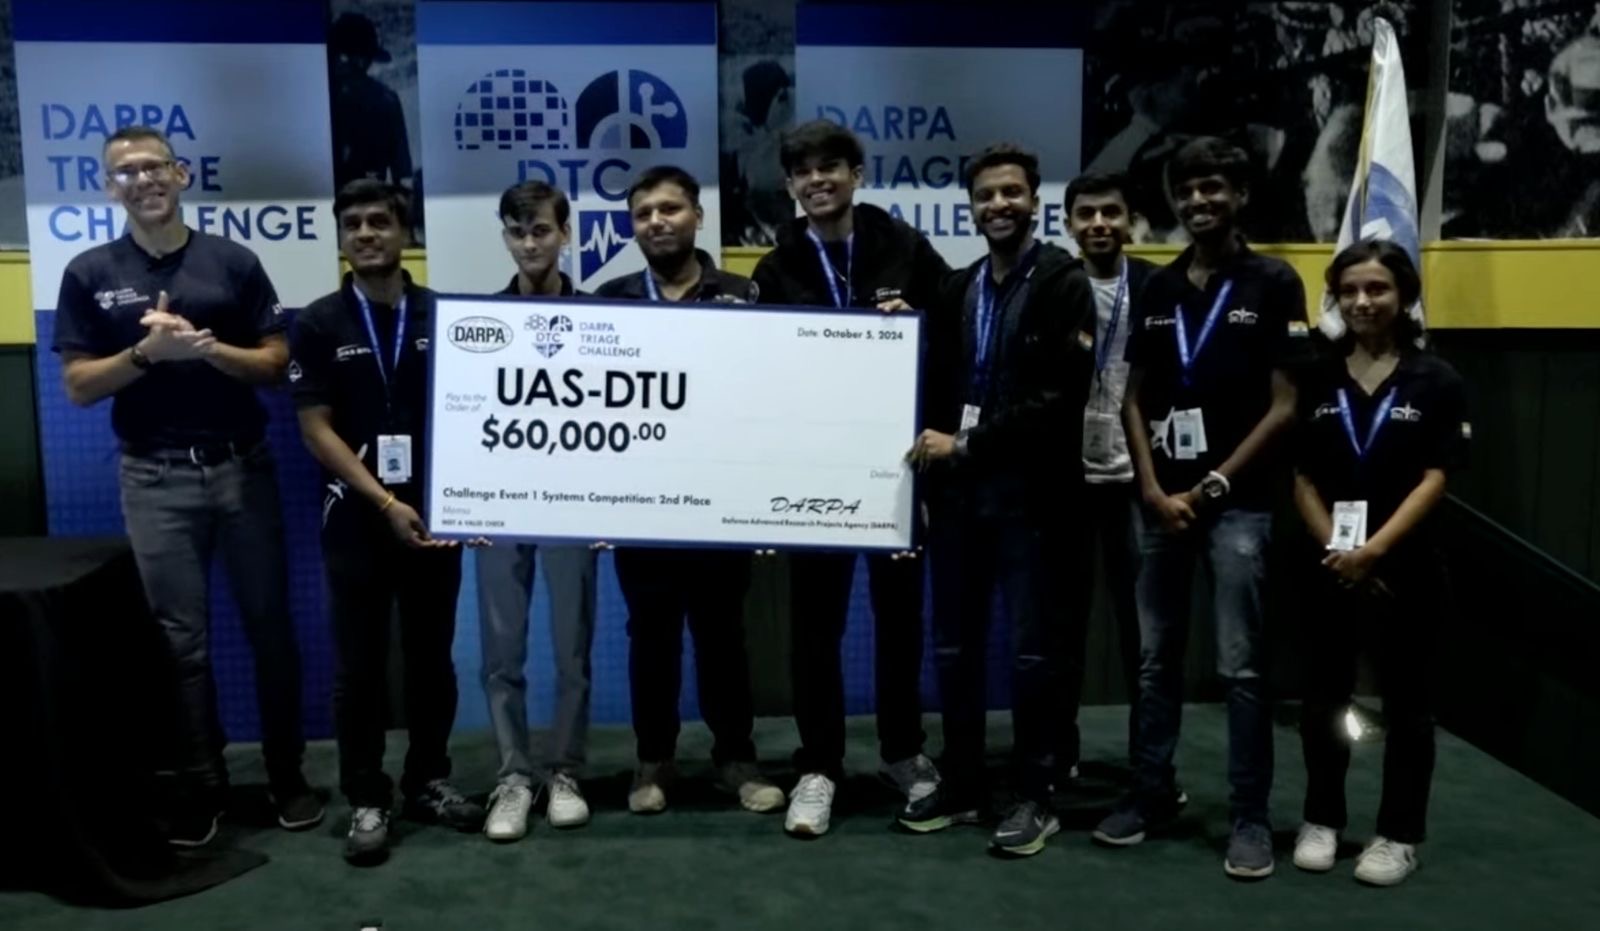
- 10/2024 Won 2nd Place ($60,000) at the DARPA Triage Challenge with Team UAS-DTU.
- 10/2024 Obtained FAA Part 107 S-UAS Pilot License.
- 05/2024 Secured 3rd Position globally and 2nd in Simulation at the ICUAS UAV Competition in Greece.
Experience
More Info
- Implemented and extended WildOS-based semantic exploration, enabling quadrupeds to discover frontiers, maintain navigation graphs, backtrack dead ends, and reach goal locations autonomously.
- Implemented semantic terrain-aware planning using Mask2Former, enabling physical quadrupeds to avoid rivers and dense bushes while preferring traversable regions.
- Improved factor-graph VIO to handle IMU impulses induced by quadruped foot-ground impacts.
- Improved robustness to jerky motion, dynamic foliage, moving shadows, and tall vegetation.
- Achieved 30% lower Z-drift and lower ATE than ZED SDK over 1 km+ outdoor and multi-floor indoor runs.

More Info
- GPU rendering platform built on top of distributed compute with near-unlimited scale.
- Renders massive scenes across hundreds of GPUs globally in parallel.
- Up to 80% lower cost and 10x faster than traditional render farms.
- Used by 100+ animators, VFX studios, and artists worldwide, generating six-figure monthly revenue.

More Info
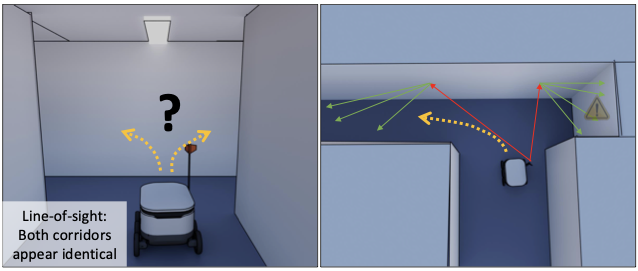
- Developed SuperEx that enables robots to see beyond line-of-sight using SPAD-based NLOS sensing.
- Modeled a CUDA-accelerated real-time physics simulator for 360 multi-bounce photon scattering.
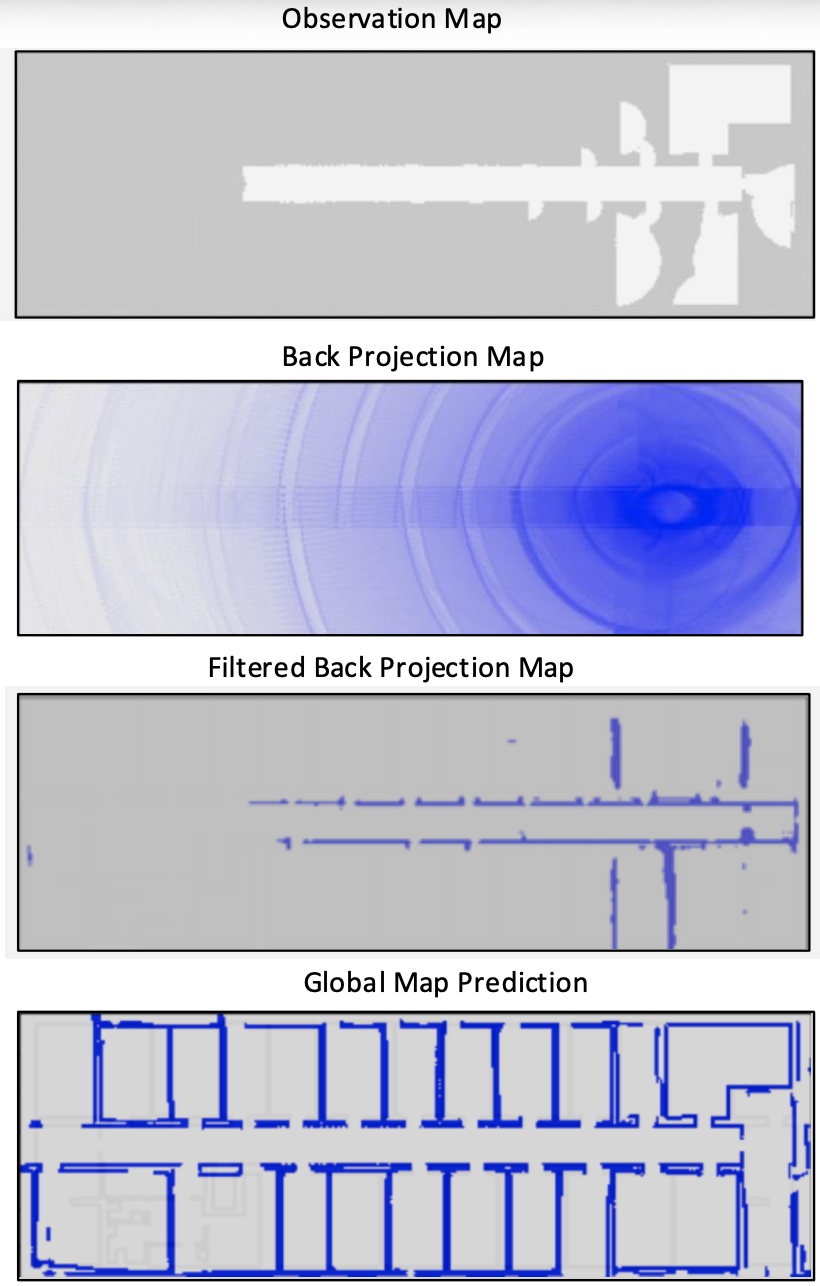
- Trained a GAN to reconstruct occluded geometry from noisy backprojection maps of NLOS data.
- Trained a LaMa-based inpainting model to predict complete indoor floor layouts from NLOS observations.

More Info
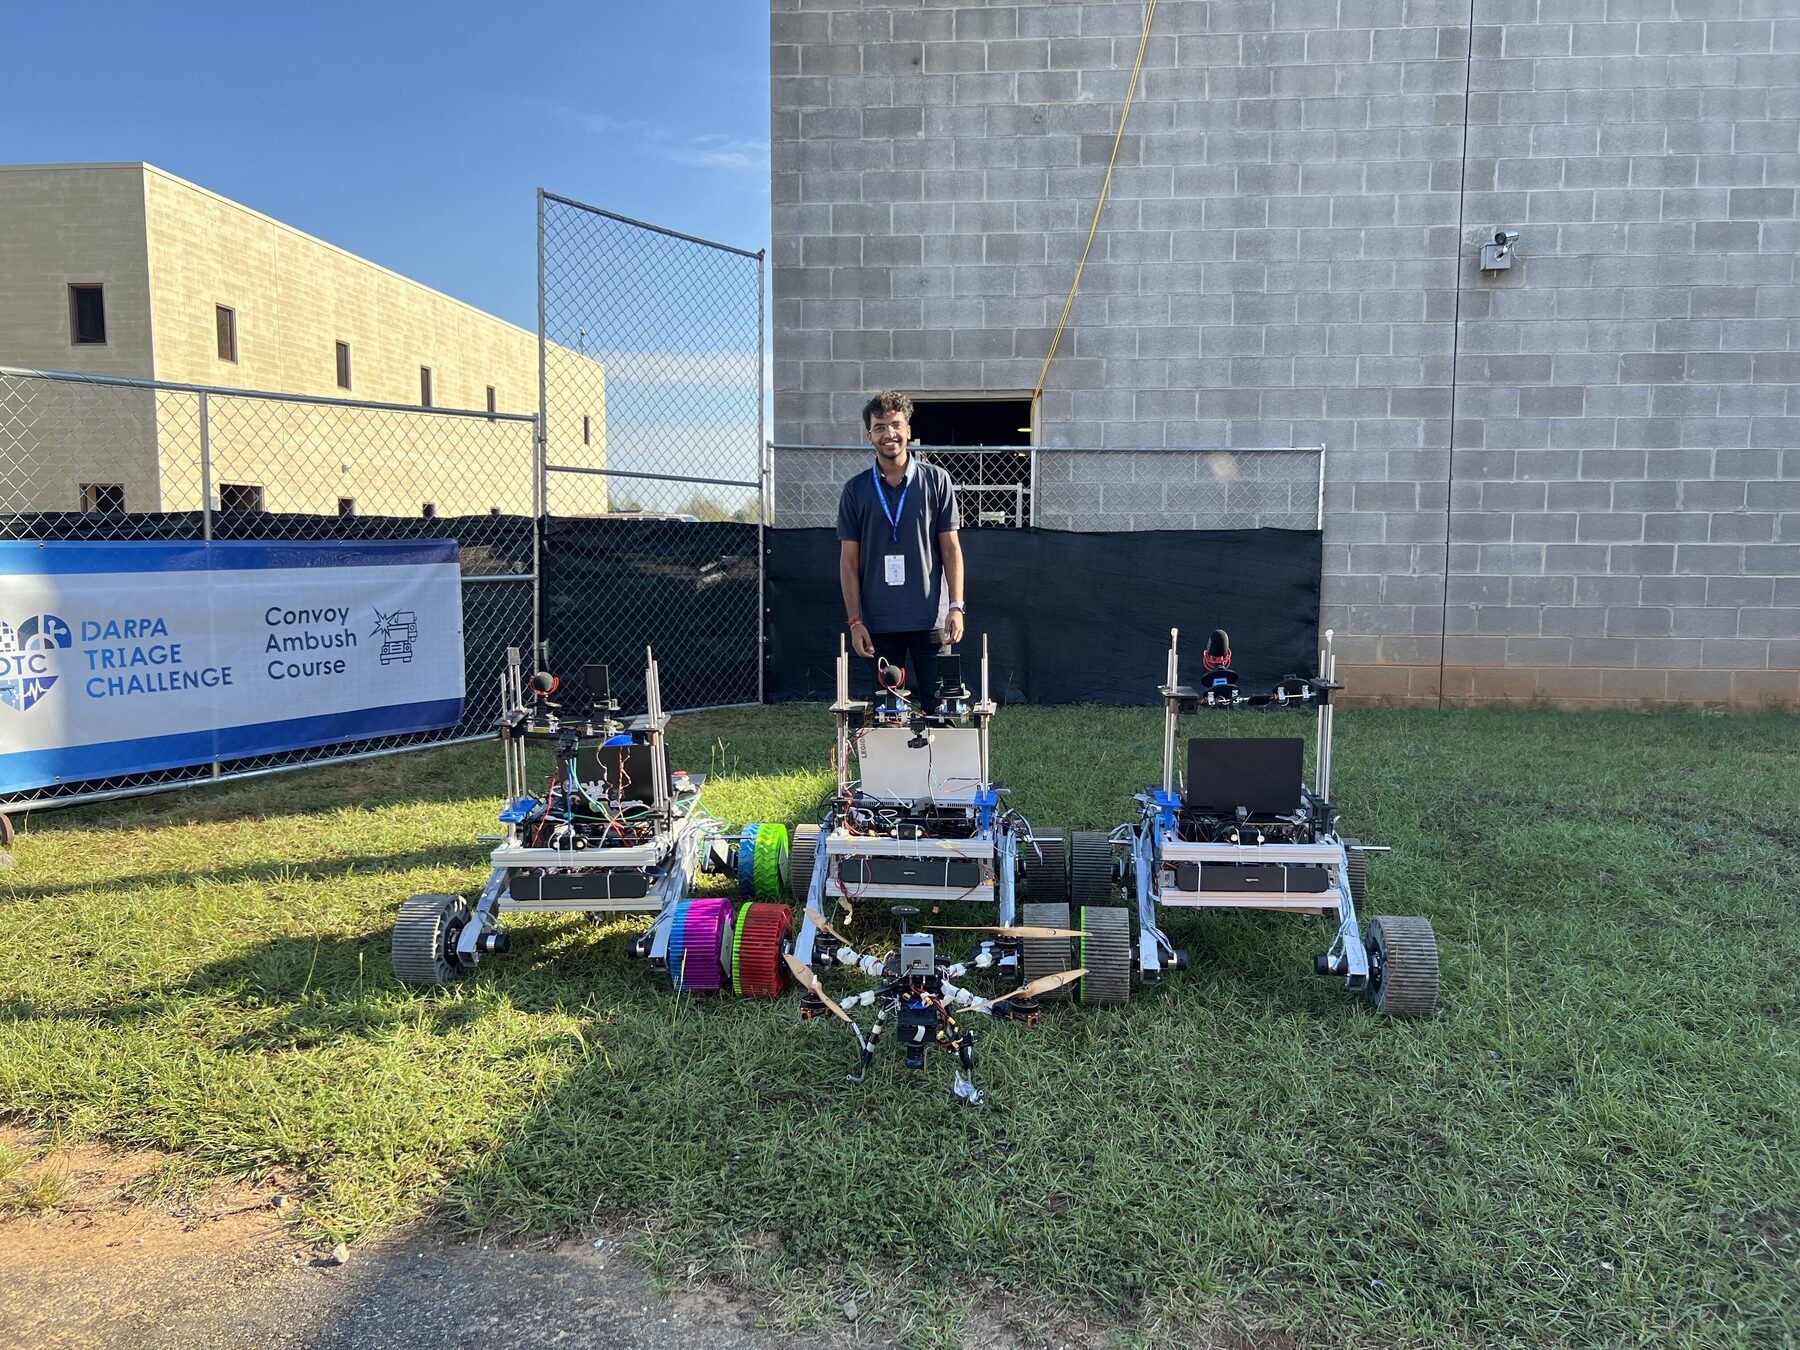
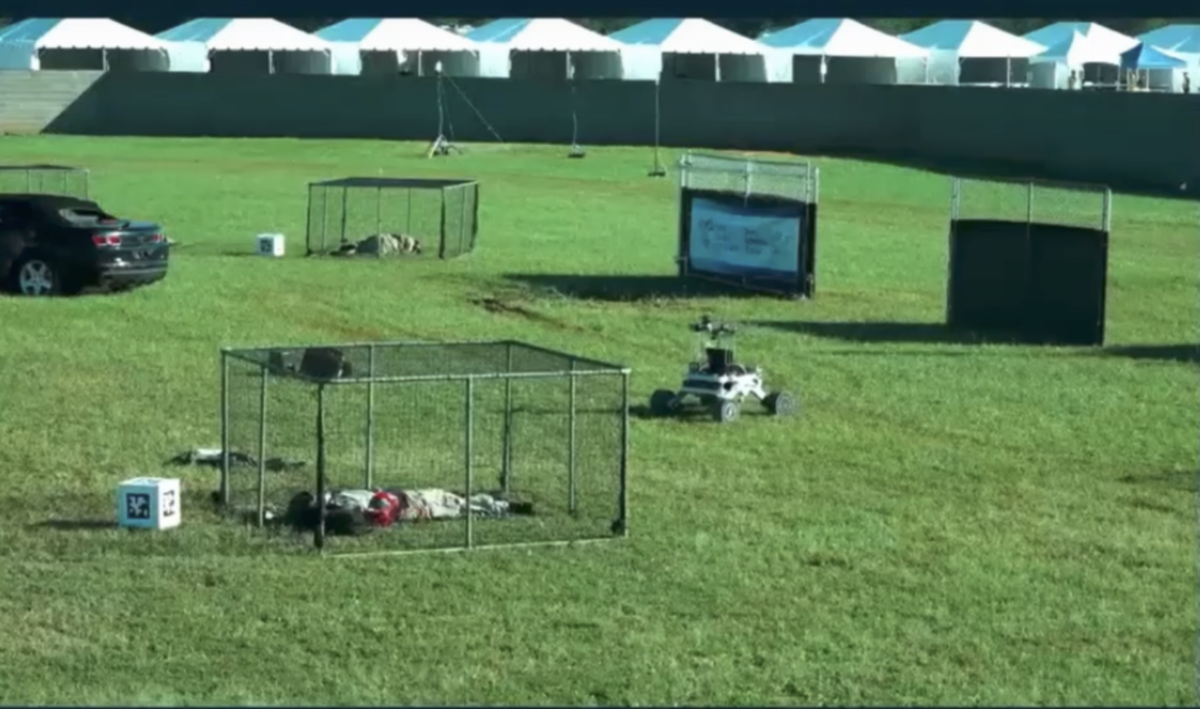
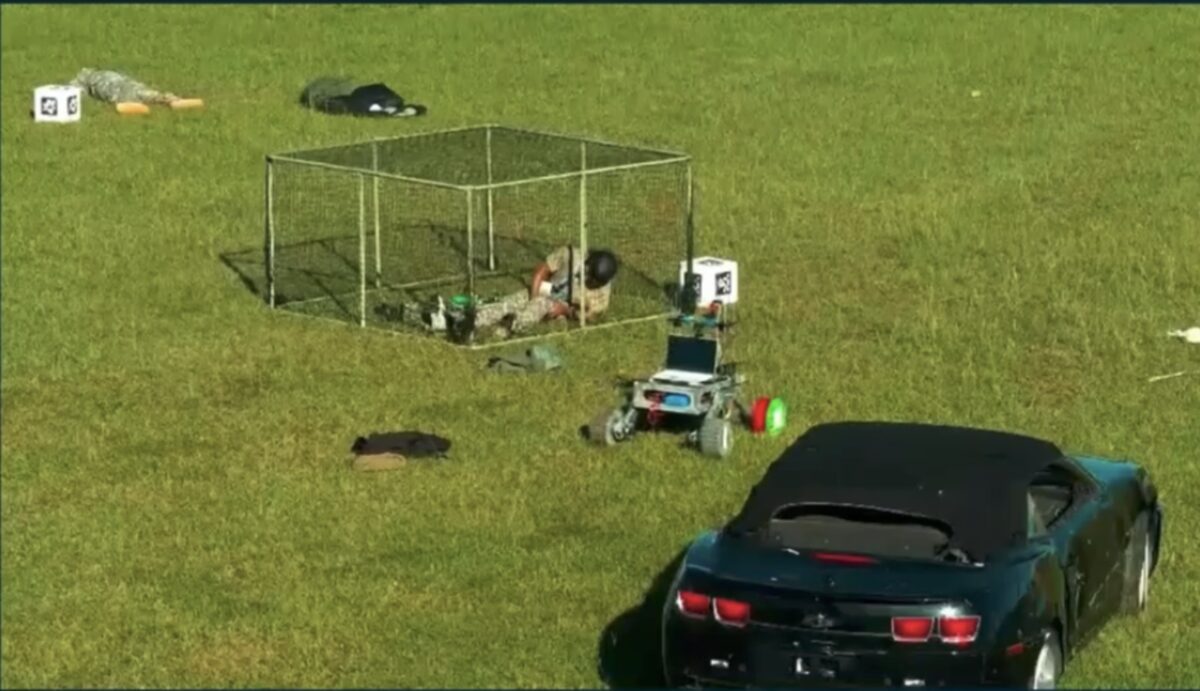
- Placed 2nd and won a $60,000 prize as a self-funded team in a U.S. Department of Defense competition.
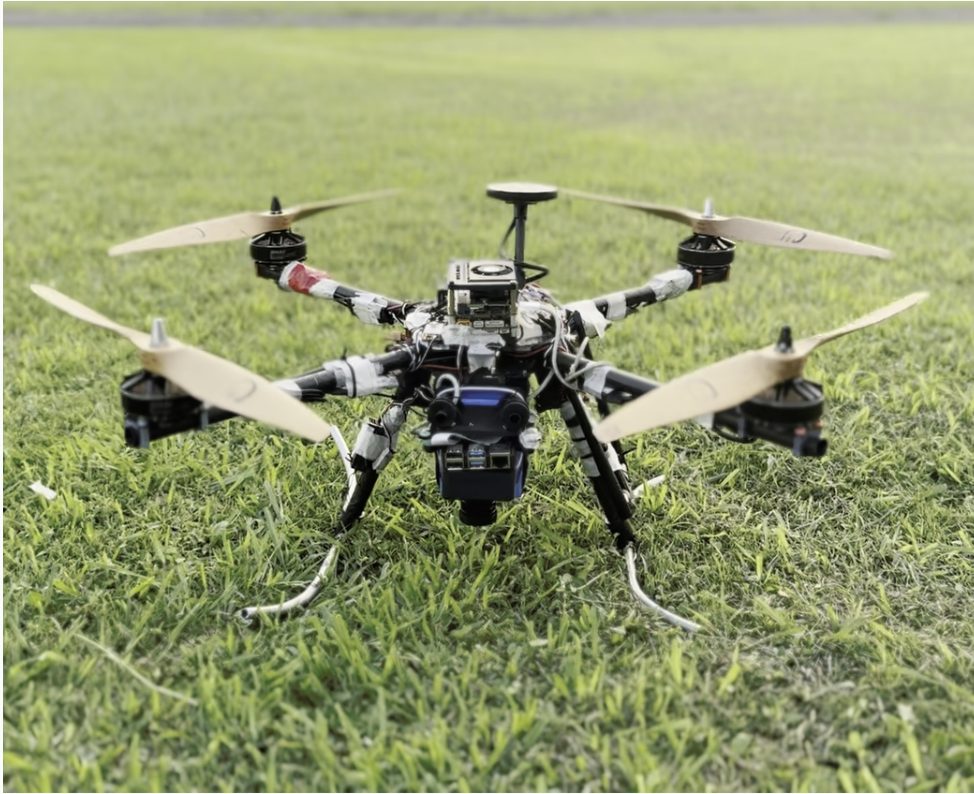
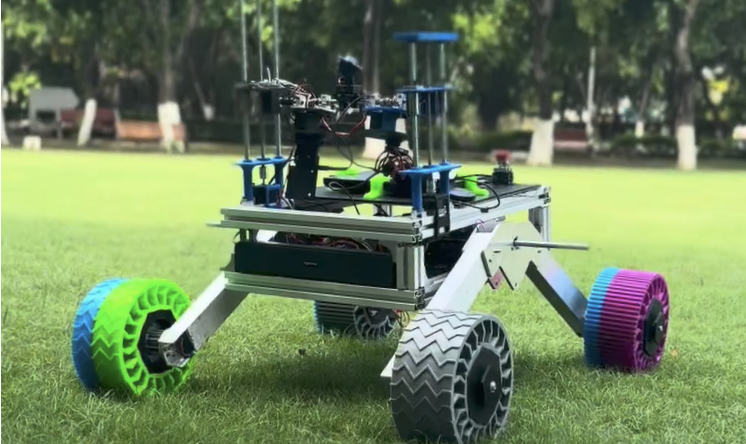
- Engineered UAV and 3 UGVs integrating LiDAR, radar, cameras for autonomous casualty assessment.
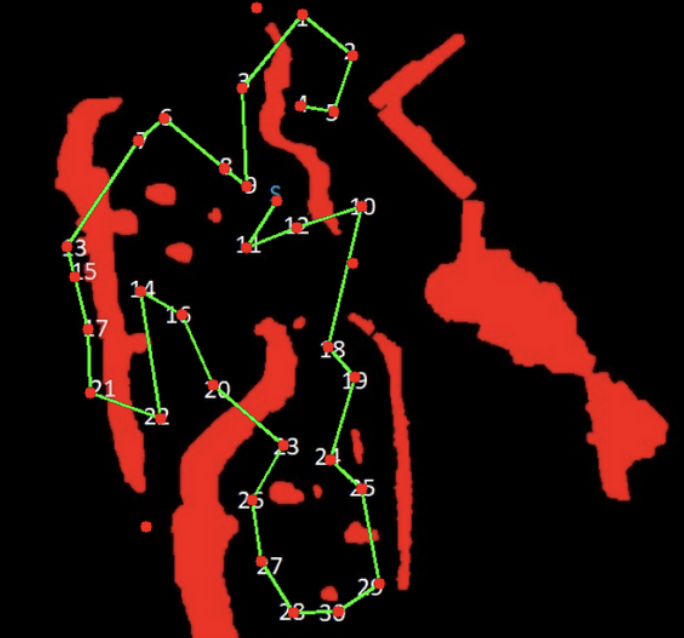
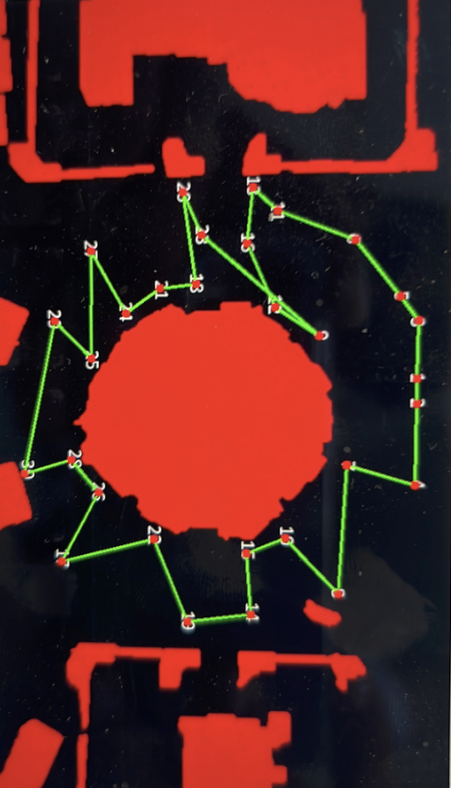
- Designed multi-agent coordination strategies and developed a hybrid path-planning algorithm.
- Built a UAV geolocation pipeline with human detection achieving cm-level localization at 10 m altitude.
- Achieved autonomous, contactless assessment of real casualties using SLAM, path planning, and deep learning to estimate breath rate, heart rate, trauma, hemorrhage, and AVPU alertness from 1 m standoff.

More Info
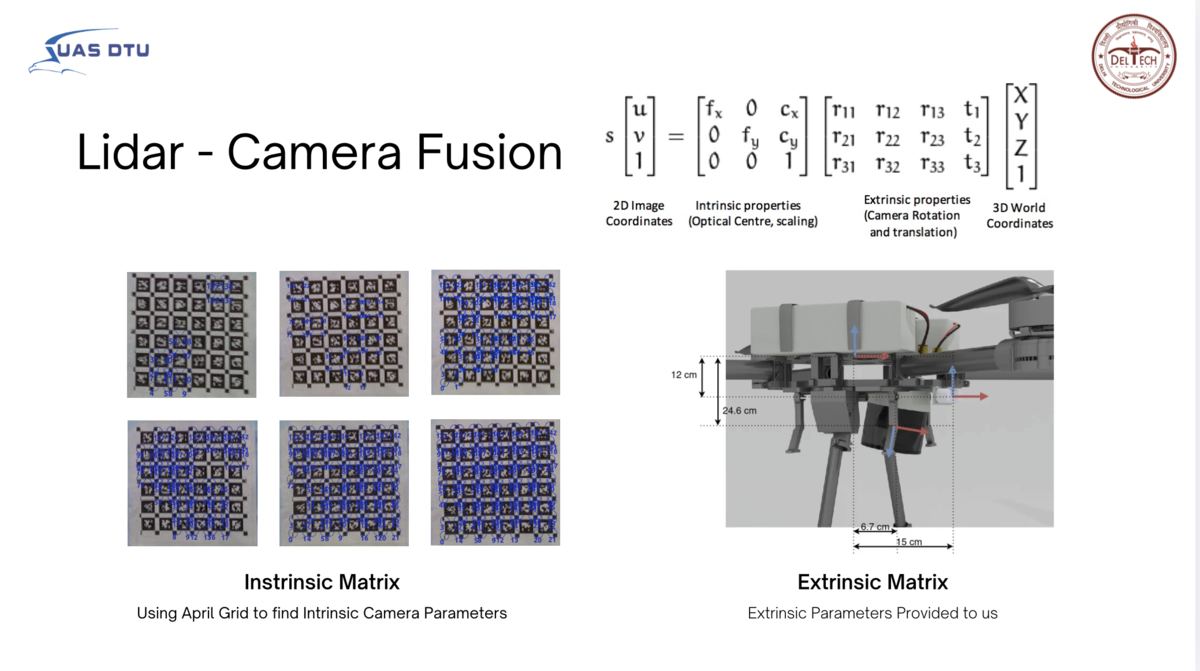
- Secured 3rd position globally and 2nd in simulation for developing an autonomous fruit-counting UAV.
- Implemented LiDAR–camera fusion for fruit counting and mapping in ROS2 with a hybrid A* TSP planner.
- Achieved 98% accuracy in simulation & 90% accuracy in real-world implementation.
- Stack: ROS2, Gazebo, LiDAR-camera fusion, mapping, path planning, and clustering.
- Sensors: Intel D455 and Velodyne VLP-16.

More Info
- Built autonomous UAV systems implementing SLAM, sensor fusion, RL and onboard control stacks.
- Executed 100+ hours of automated missions with Mission Planner and SITL-Gazebo workflows.
- Designed and fabricated quadcopters, VTOLs, fixed-wings, and rovers with comm systems.
- Developed ROS pipelines and deployed RealSense D455 for autonomous navigation and mapping.
Awards & Recognition
- Won 1st place nationally among 48,000+ applicants and received a ₹6 lakh scholarship for the Context-Aware Assistive Wearable for Neurodivergent Children.
- Licensed to operate small unmanned aircraft systems in the United States.
Publications
More Info
- A framework for indoor mapping and exploration that uses non-line-of-sight sensing.
- Uses single-photon LiDAR to carve empty NLOS regions and reconstruct nlos region.
- Combines Pix2Pix and LaMa with global map prediction to improve frontier exploration.
- Reported a 12% gain in mapping accuracy under 30% coverage on simulated maps.
Projects
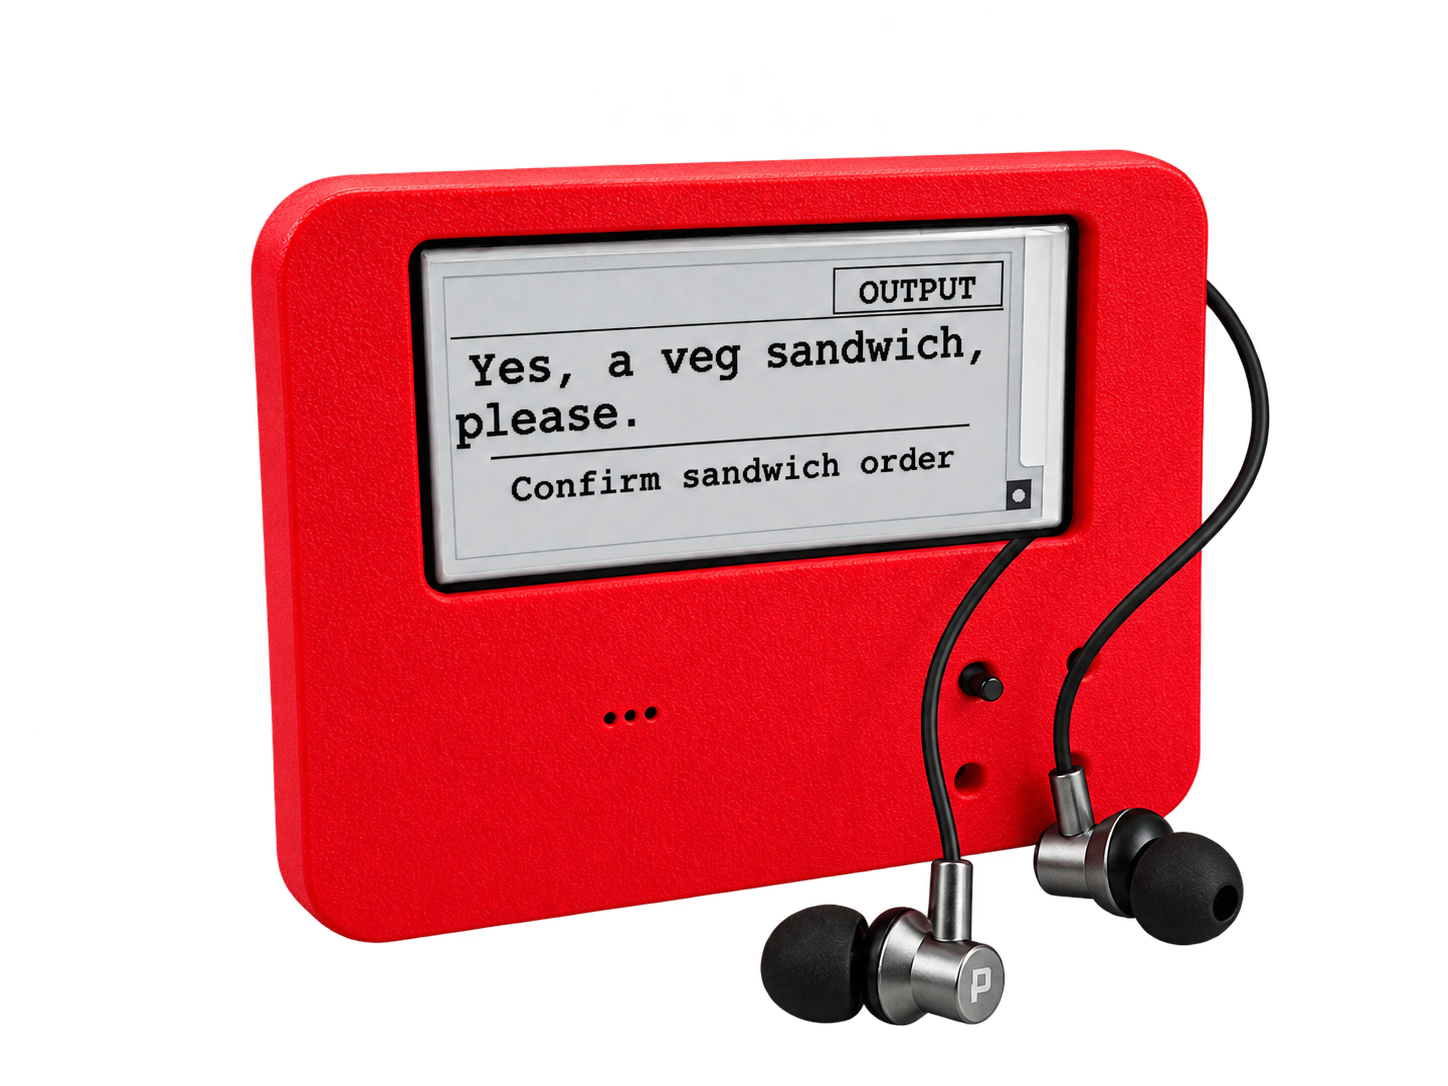
Context-Aware Assistive Wearable for Neurodivergent ChildrenESP32-S3, E-paper Display, Speech Recognition, Language Models
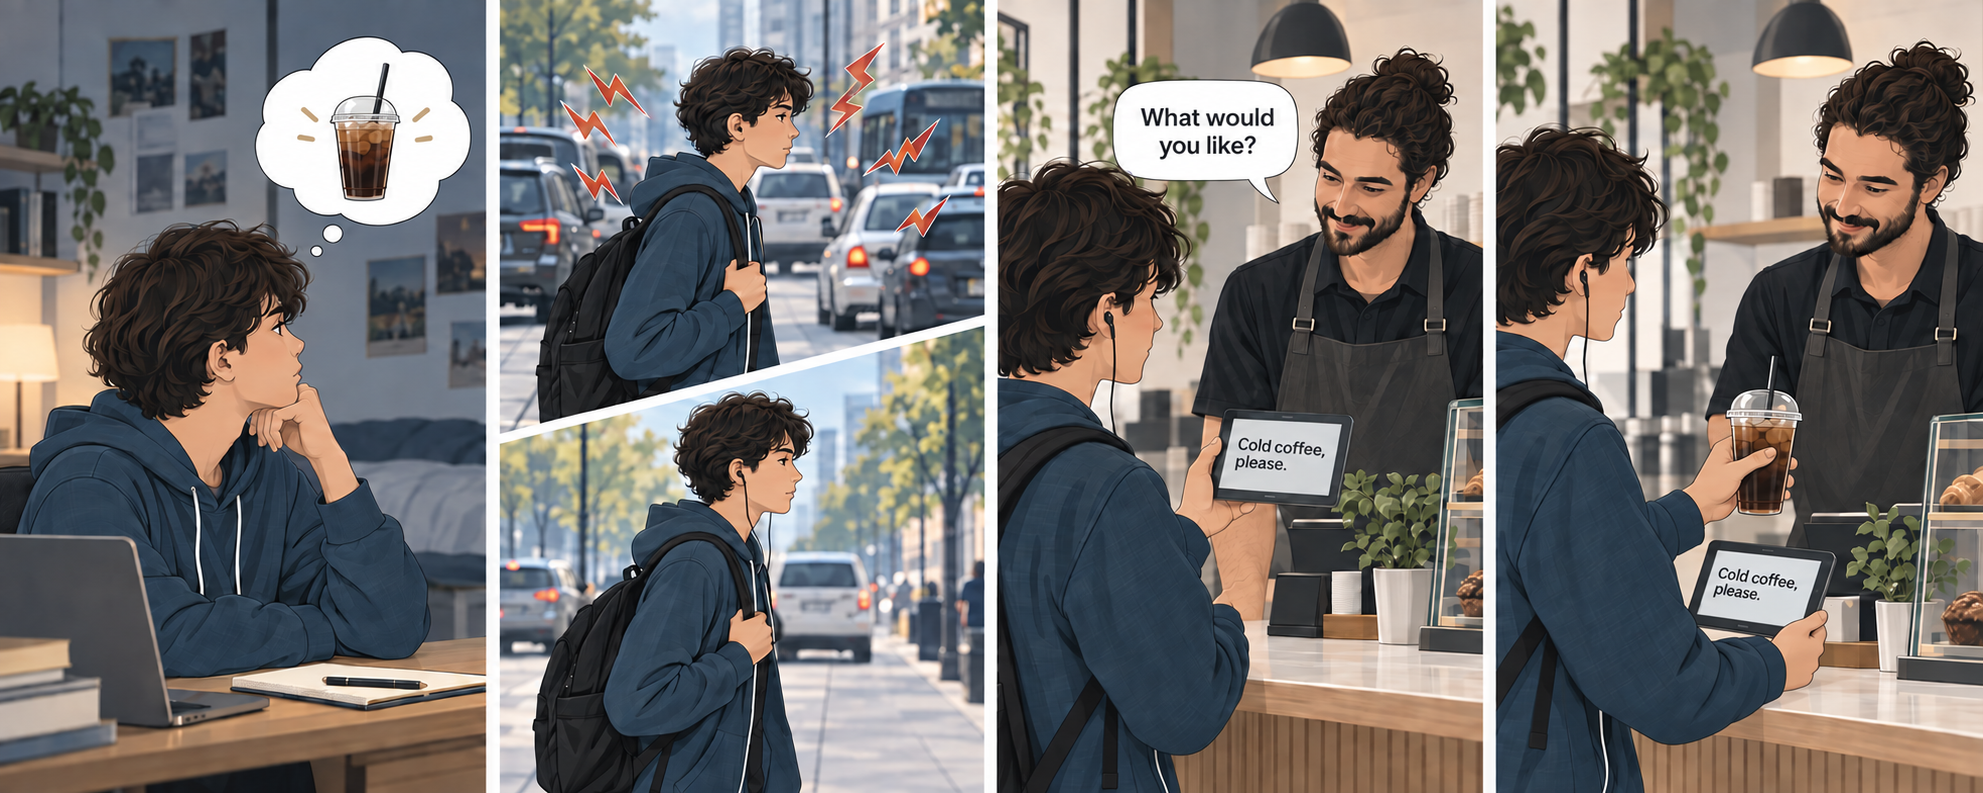
- Built a small wearable that helps neurodivergent children communicate in everyday situations without needing to speak or navigate a complex phone screen.
- With one button press, it listens to the conversation, understands the immediate context, and shows a short suggested response on a calm e-paper display.
- It can also make traffic noise less distracting through wired earphones, while keeping nearby speech understandable.
- Designed privacy-first controls that keep recent conversations separate from confirmed personal preferences, so the wearer stays in control.
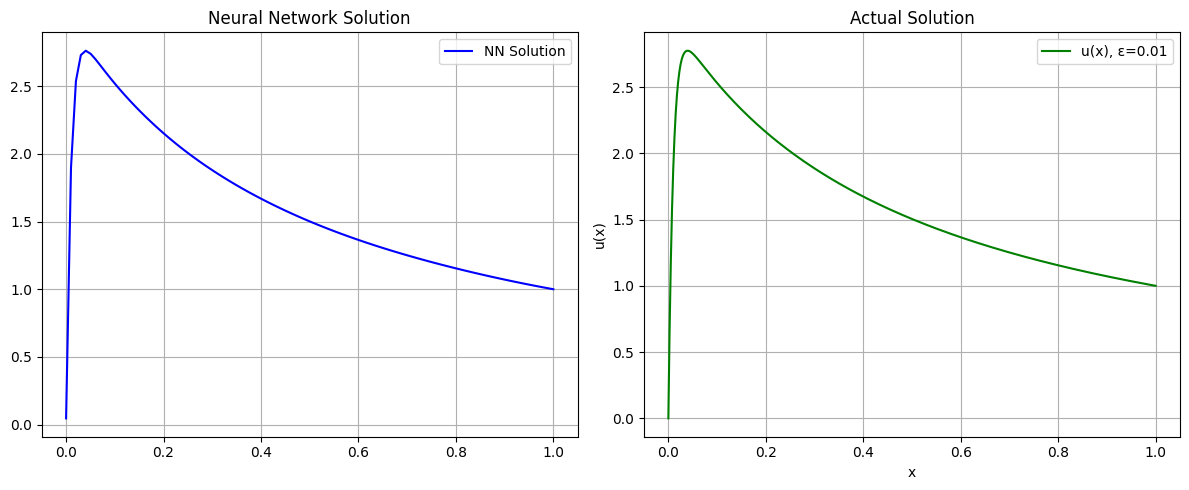
Physics-Informed Neural Networks for Singular Perturbation ProblemsPyTorch, PINNs, ODEs
- Developed an adaptive moving-mesh PINN architecture to solve singularly perturbed ODEs with sharp boundary layers and stiff solution regimes.
Aerial Human Detection and Geo-localizationQuadcopter, PiCam, GPS, IMU, Python
- Implemented PiCam-based human detection with intrinsic–extrinsic calibration and IMU correction.
- Achieved cm-level geo-localization by fusing GPS, camera transforms, and UAV state estimates.
Drone On Time – Autonomous Drone Delivery SystemIncubated at DTU Innovation and Incubation Foundation
- Built an autonomous medical drone delivery system achieving 75% cost and 70% emission reduction.
- Completed 25+ successful autonomous deliveries carrying upto 2 kg payloads over a 10 km range.
Dynamic Multi-UAV Obstacle AvoidanceROS2, Gazebo, MAVROS, Ardupilot, Python
- Built a ROS2–Gazebo obstacle avoidance pipeline using Velodyne 360° LiDAR point clouds.
- Enabled 15 m/s collision-free flight via MAVROS–ArduPilot integration and dynamic avoidance.
- Stack: ROS2, Gazebo, MAVROS, and APFA.
Skills & Platforms
Education

More Info
- Computer Science: Artificial Intelligence, Machine Learning, Computer Vision, Data Structures & Algorithms, Operating Systems, Computer Networks, Theory of Computation.
- Mathematics: Linear Algebra, Modern Algebra, Differential Equations, Probability & Statistics, Stochastic Processes, Discrete Structures, Complex Analysis, MATLAB.
- Academics Head, Mathematics and Computing Community, DTU.

More Info
- Vice President, Tech Society, Modern School Barakhamba Road.
Gallery